
Pick complete robots or single parts and download a ready-to-print package — oriented STLs, ready 220 × 220 mm plates and the PrusaSlicer profile every part was verified with.
Open the print kit
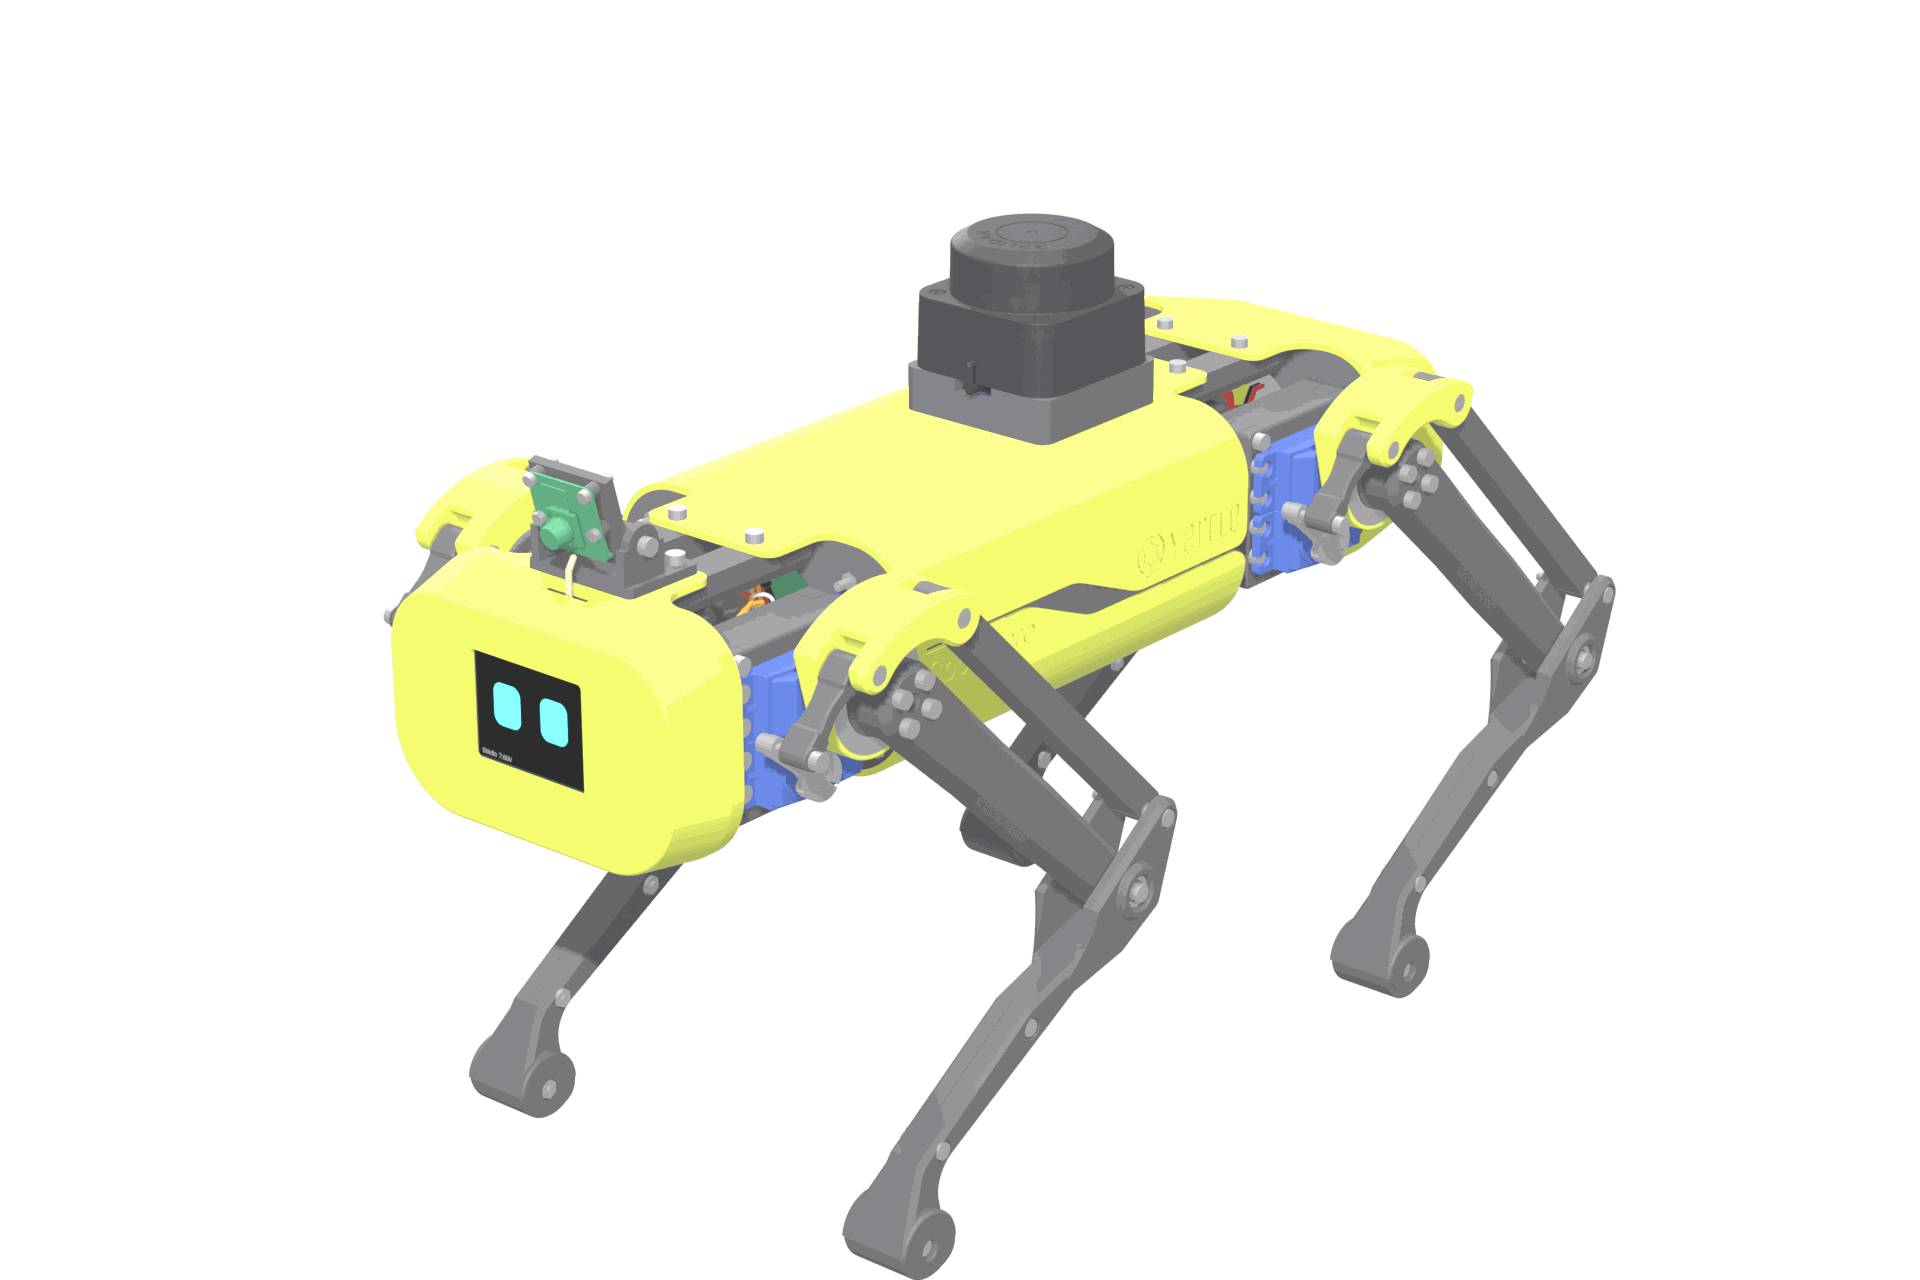
Mini-Pupper-class robot on proven Yertle legs, with a face display, 360° LiDAR, wide camera, Raspberry Pi 5 + ESP32-S3, ROS 2 and a learned controller. Every part, bolt, pin and joint limit comes from a verified CAD model.
Pick complete robots or single parts and download a ready-to-print package — oriented STLs, ready 220 × 220 mm plates and the PrusaSlicer profile every part was verified with.
Open the print kit
The complete robot as one cart, priced at real shops with shipping. Choose one of four buying plans or change the shop per part; check out per shop, Amazon in one click.
Open the shop
IKEA-style steps generated from the CAD — each part and fastener appears in exactly one parts box; fasteners drawn at 1:1 in the PDF.
Assembly manual
Power tree, wiring list, pin map and power budget, checked against the firmware pin header and every fuse and wire rating.
Electronics
ESP32-S3 firmware with watchdog and e-stop, ROS 2 Jazzy bringup, MuJoCo and Gazebo models from the CAD, PPO training and an NT-X extension.
Software
A wiki on the engineering behind the robot — servos, LiPo power, buses, sensors, Linux, Docker, ROS 2, kinematics, reinforcement learning, 3D printing and fasteners.
Start learning